Move the leader by hand, the robot follows.
A GELLO-based teleoperation system built at Parametric—hand-driven leader arms that mirror a pair of i2rt YAM manipulators in real time, built for collecting bimanual manipulation episodes.
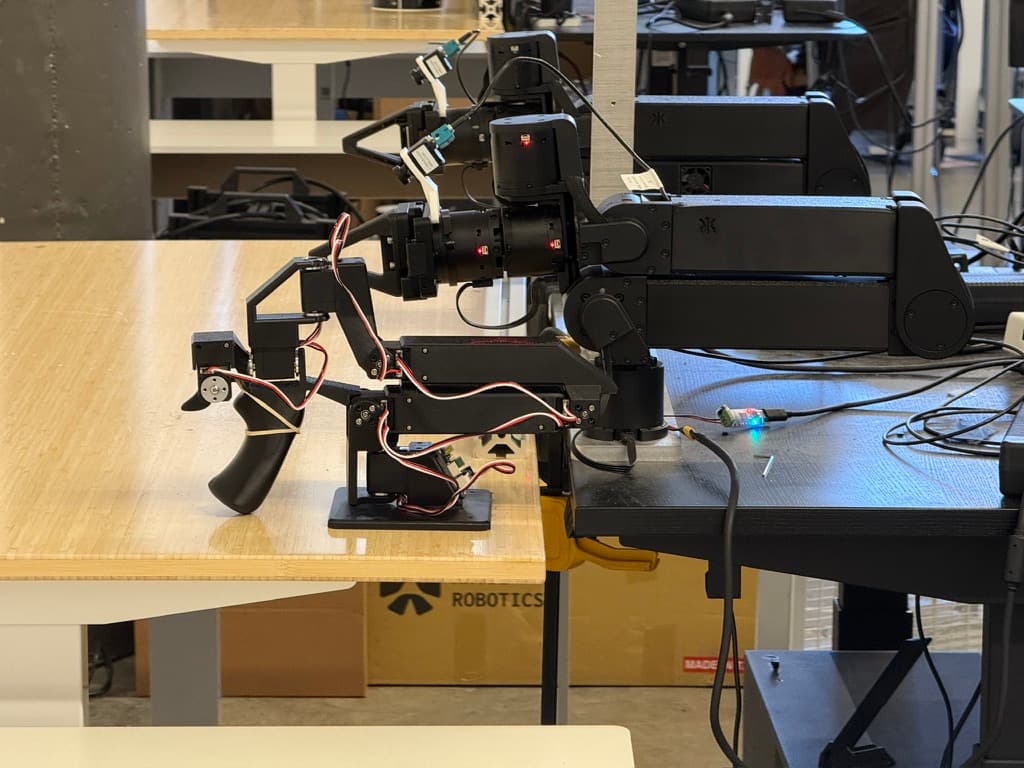
Collecting the episodes and interventions a policy learns from.
Manipulation policies are only as good as the episodes they are trained on, and collecting those episodes is a major bottleneck. A kinematic replica of the manipulator, a GELLO teleoperation system allows for a lightweight and cost efficient solution to dexterous manipulation tasks, as the followers mirror the motion in real time.
Part of the design was later open-sourced as Pello, Parametric's public release of the leader arms, outlined below.
A robust and ergonomic design.
The leader terminates with a handle and trigger that maps directly to the follower's end-effector. The 5/8 scale GELLO offers an ergonomic form factor for extended teleoperated data collection sessions. Additionally, the backdrive friction of the servos has been tuned to be stiff enough the arm won't collapse under its own weight, but free enough for precise control.
- Five printed PETG linkages (L1–L5) off a flat base (L0), each joint carrying a servo that provides its own position feedback
- Gripper trigger sprung normally open (NO) by a rubber band, so releasing the trigger opens the follower's gripper
- Mechanical hardstops prevent the GELLO from exceeding the range of motion of the manipulator and provide each arm a reliable home for zeroing before and after each episode.
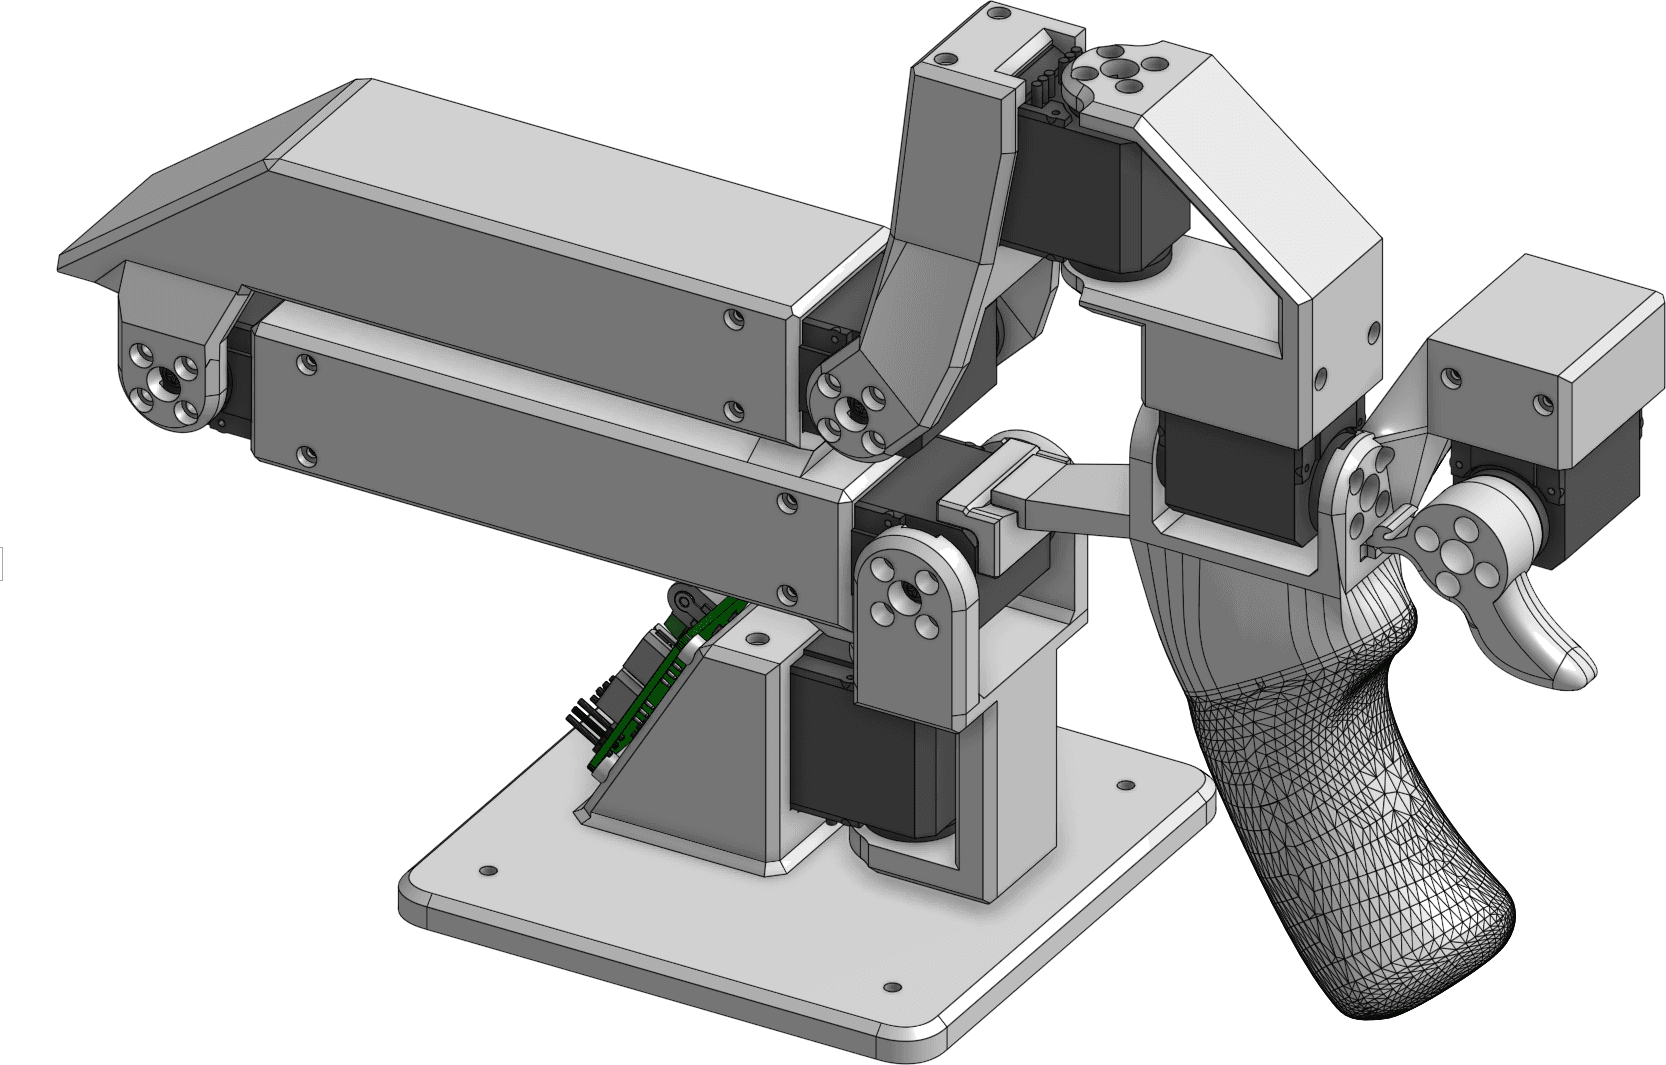
A 5/8-scale, 6-DOF replica of the i2rt YAM.
The GELLO leader arm is a 5/8-scale replica of the 6-DOF i2rt YAM, sensed by 7 Feetech STS3215 serial-bus servos per arm—each providing magnetic position feedback.
The servos communicate over a shared serial bus into a Waveshare serial-bus driver board at the base of each arm, which connects to the host machine over USB-C.
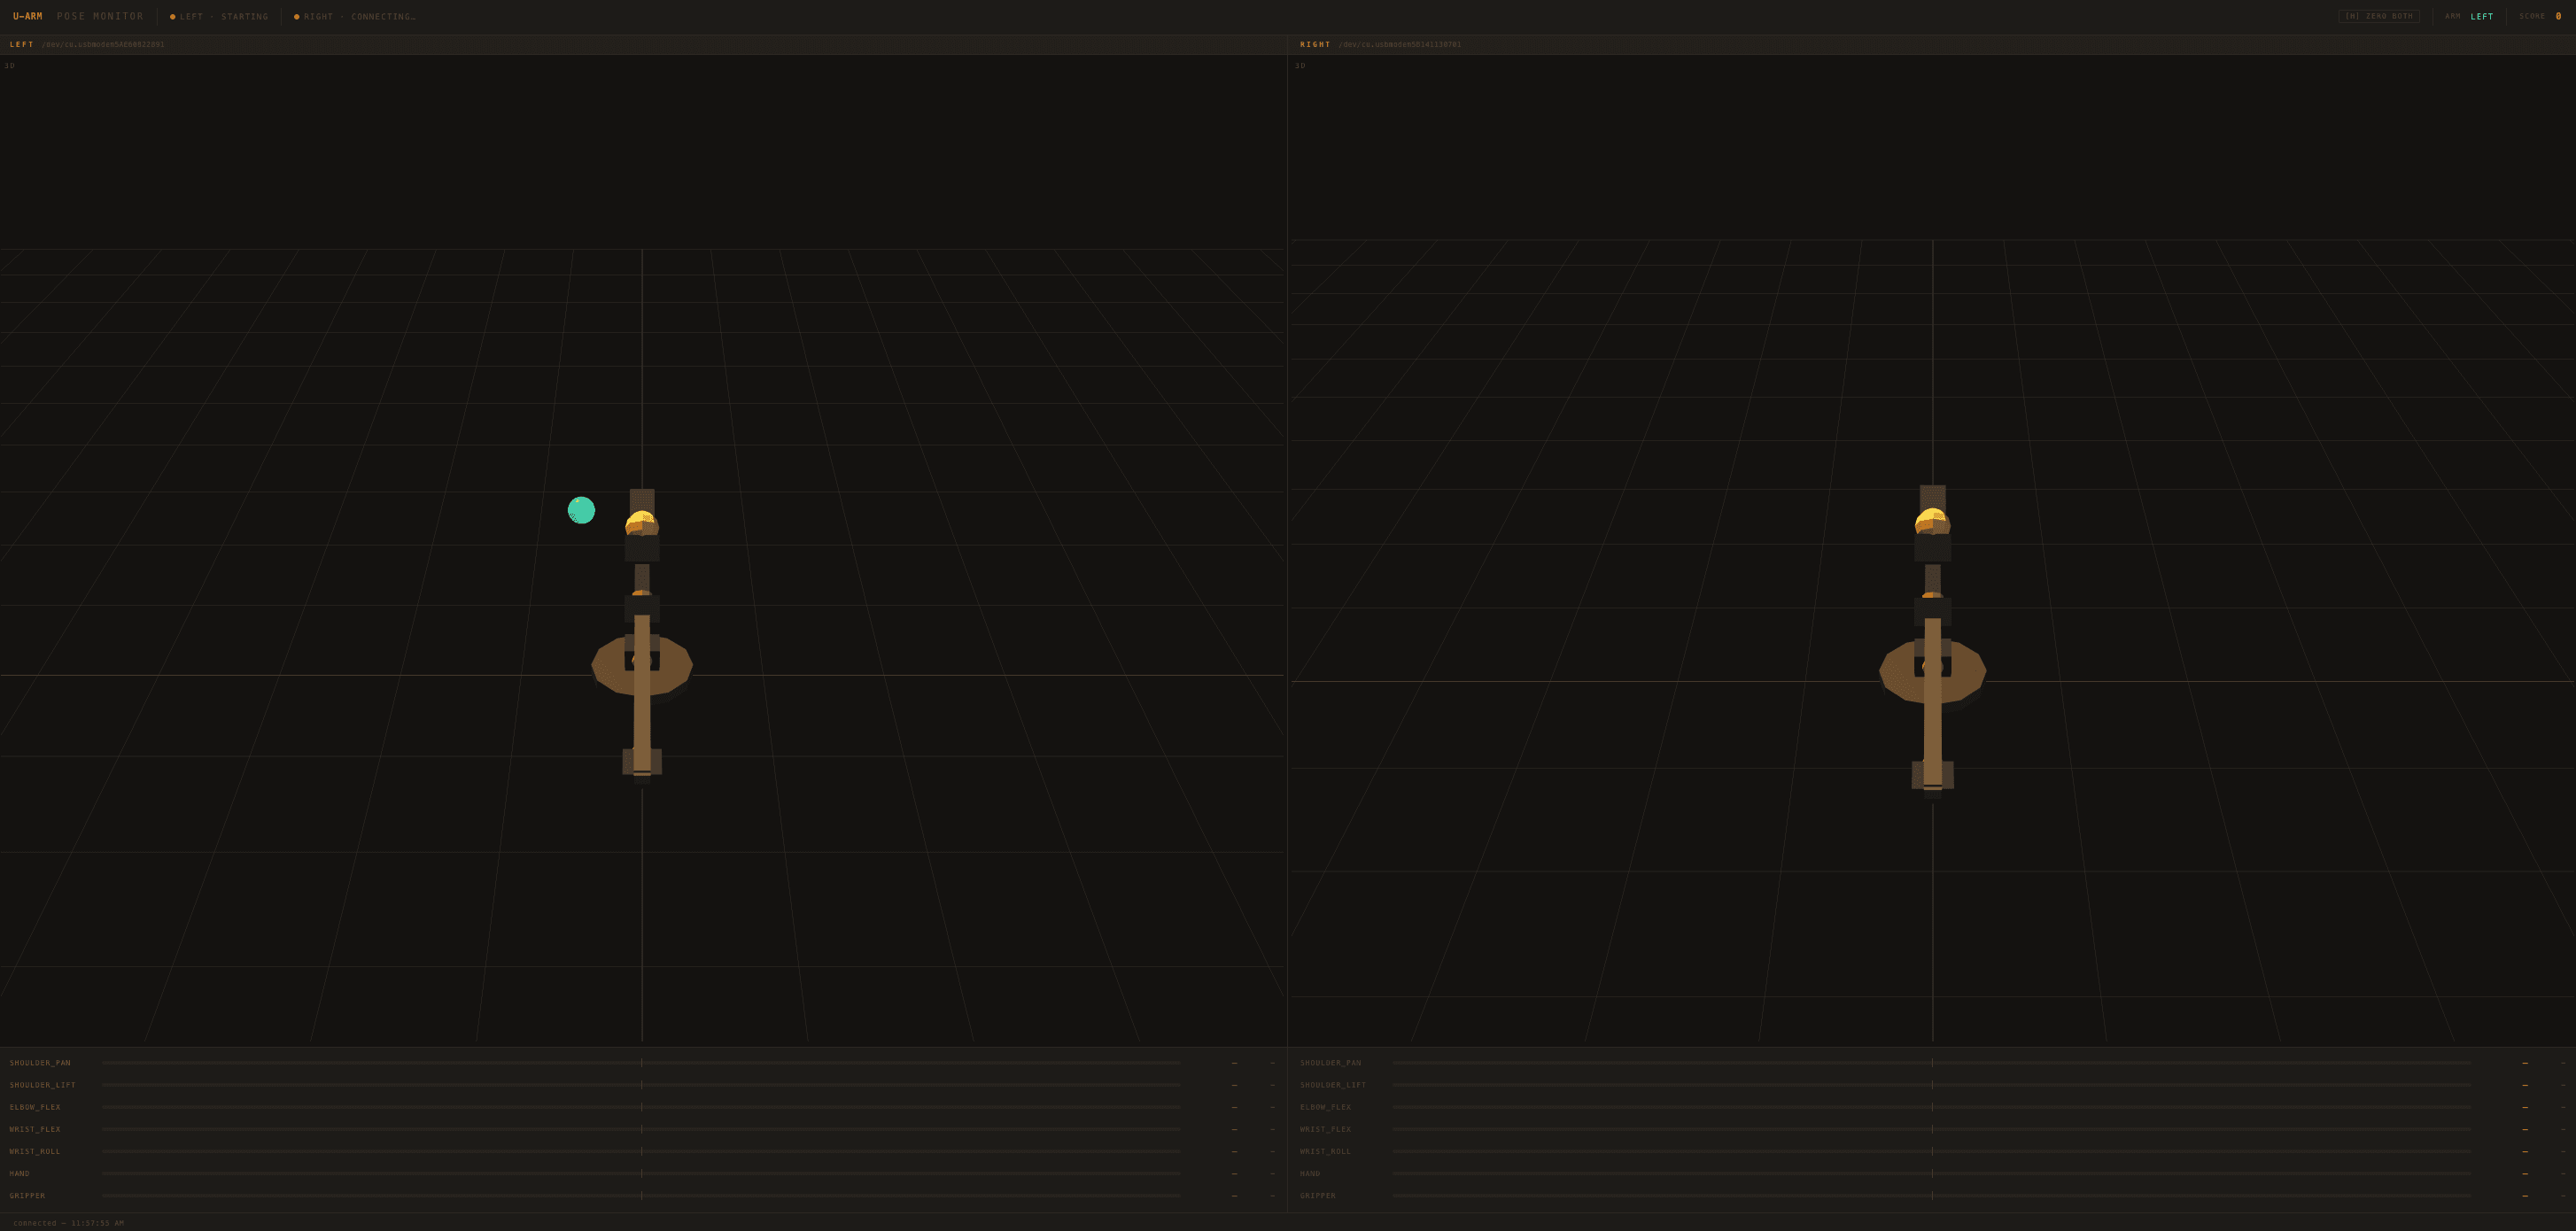
A companion pose-monitor GUI subscribes to that same servo state over a WebSocket connection and renders both arms live in a 3D view, auto-zeroing on the first frame and re-zeroable on demand that allows for stress testing before GELLOs are deployed to drive followers.
Test a build before it collects real data.
Before a leader ever drives a follower, the same pose-monitor GUI doubles as a validation step. It exercises each servo and confirms its ID assignment on the shared bus, catching wiring or configuration issues before the arm is trusted to collect data on real manipulators.
One leader set, two arms, $373.93.
| Component | Qty | Price |
|---|---|---|
| Feetech STS3215 servo | 14 servos | $315.96 |
| Serial bus servo driver board (Waveshare, 2-pack) | 1 pack (2 boards) | $19.99 |
| Power supply (SHNITPWR 60W adjustable) | 2 | $37.98 |
| Total (one leader set / 2 arms) | $373.93 | |
Not included: the 3D-printed parts (~800g PETG, ~$14 in filament) and common consumables (glue, heat-set inserts, USB-C cables). Full breakdown in the pello repo.